Author's Homepage: R. C. Hibbeler
Chapter 17: Planar Kinematics of a Rigid Body: Force and Acceleration
"Since a body has a definite size and shape, an applied non-concurrent force system may cause the body to both translate and to rotate. The translational aspects of the motion were studies in Chapter 13 and are governed by the equation F = ma. It will be shown in Sec. 17.2 that the rotational aspects, caused by a moment M, are governed by an equation of the form M= I alp. The symbol I in this equation is termed the moment of inertia. By comparison, the moment of inertia is a measure of the resistance of a body to angular acceleration (M = I alp) in the same way that mass is a measure of the body’s resistance to acceleration (F = ma)."


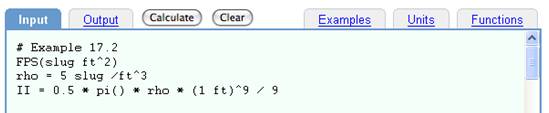
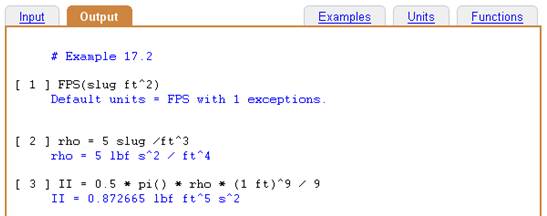
 or by typing Shift Enter.